Check the package
One P60 LiDAR unit; cable / connector accessories are confirmed against the delivered configuration.
Confirm delivery →LIDAR
360° × 60° FOV · repetitive scanning · 960,000 points/s · 5 cm minimum range · -40°C to +60°C
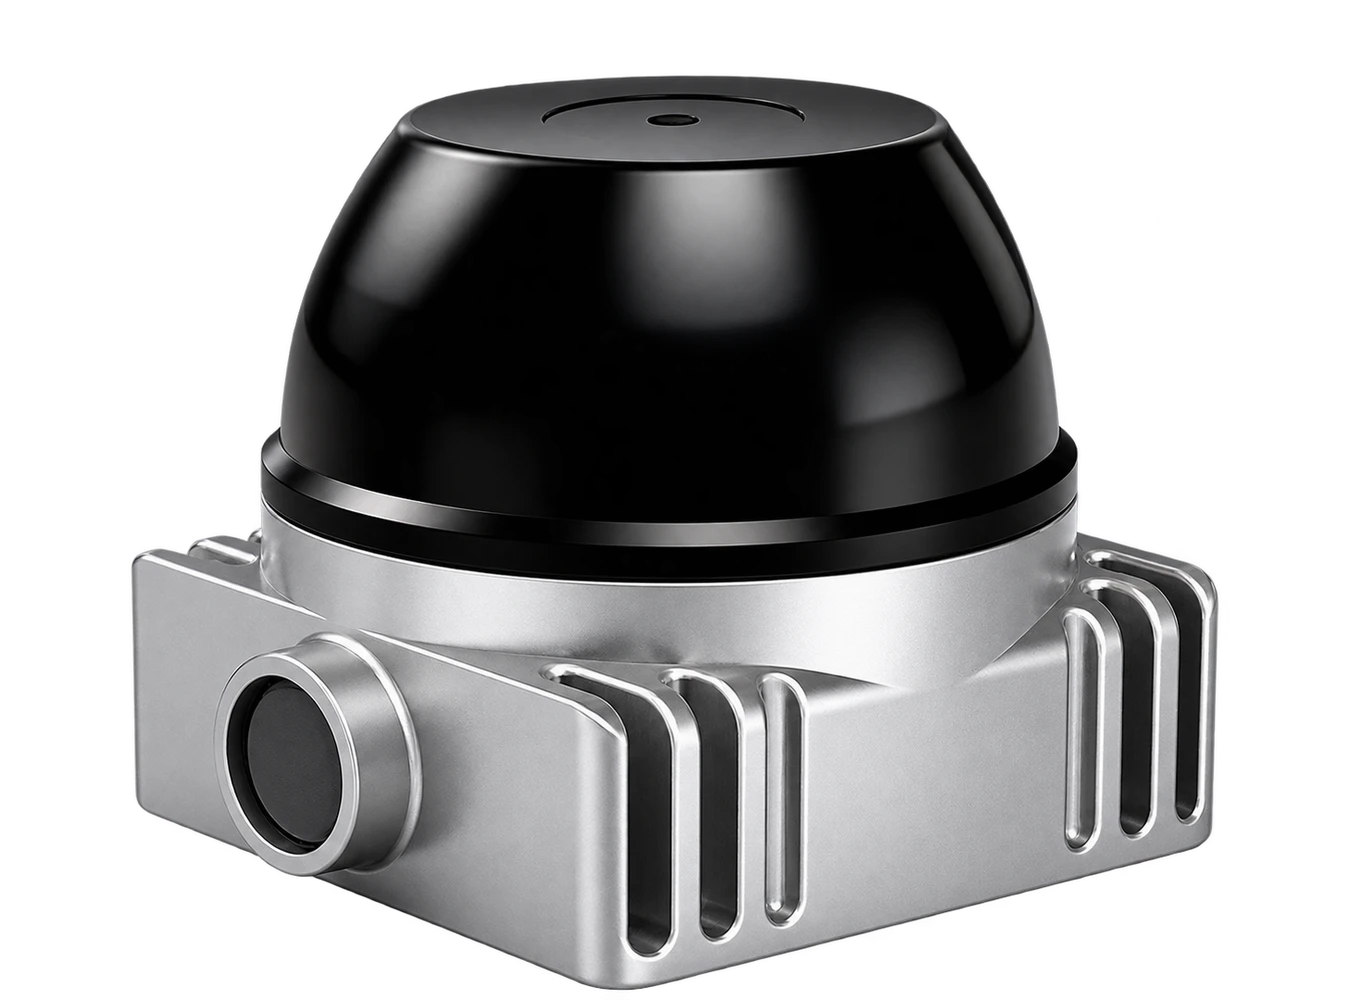
Check included items, availability and delivery before placing your evaluation order.
Model-specific values and test conditions.
| Parameter | Published value / condition | Ref. |
|---|---|---|
| Technology platform | VCSEL + SPAD dTOF | 1.1 |
| Scan lines | 96 lines | 1.1 |
| Field of view | 360° (H) × 60° (V) | 1.1 |
| Angular resolution | 0.36° × 0.625° @ 10 Hz | 1.1 |
| Scan pattern | Repetitive scanning · Consistent frame-level sampling for moving platforms. Timing and motion compensation remain important. | 1.1 |
| Detection range | 70-80 m · Depends on target reflectivity and environment. | 1.1 |
| Instrument range | 150 m | 1.1 |
| Bright-sunlight range | >35 m at 100 klx · Depends on target reflectivity and environment. | 1.1 |
| Blind zone / minimum range | 0.05 m (5 cm) | 1.1 |
| Accuracy | 3 cm (1σ), tested at 30 m on a 50% reflectivity target | 1.1 |
| Point rate / frame rate | 960,000 points/s / 10 Hz · Standard single-return stream; strongest or farthest return selectable. | 1.1 |
| Return configuration | Single return; strongest or farthest selectable · Simultaneous dual-return output requires customization. | 1.1 |
| Time synchronization | PPS + GPRMC | 1.1 |
| Communication | 100BASE-T Ethernet | 1.1 |
| Supply / power | DC 9-32 V / 7 W | 1.1 |
| Dimensions / weight | 65 × 65 × 61.5 mm / < 260 g | 1.1 |
| Operating temperature | -40°C to +60°C | 1.1 |
| Ingress protection | IP67 | 1.1 |
| Laser eye safety | Class 1 | 1.1 |
| Storage temperature | -40 to +85 deg C | 1.1 |
| Source claim boundary | Class 1 and IP67 are published claims; certificate / test report: TBD | 1.1 |
| IMU | Supported · Existing P60 specification, pages 2-4. | 1.1 |
| Interference resistance | Supported · Existing P60 specification, pages 2-4. | 1.1 |
| Vertical coverage limits | -10 to +50 degrees · Existing P60 specification, pages 2-4. | 1.1 |
| Signal / item | Source reference | Ref. |
|---|---|---|
| Data breakout | RJ45, Cat5e cable reference; 100BASE-T Ethernet | 1.1 |
| Power breakout | DC5521 female connector; harness description specifies a 12 V DC adapter. Product input operating range: DC 9-32 V. | 1.1 |
| PPS wire | Gray lead, LINE_PPS; electrical level and pin numbering: TBD | 1.1 |
| GPRMC wire | Purple lead, LINE_GPRMC; electrical level and pin numbering: TBD | 1.1 |
Units: mm. Source dimensions only; unavailable details are TBD.
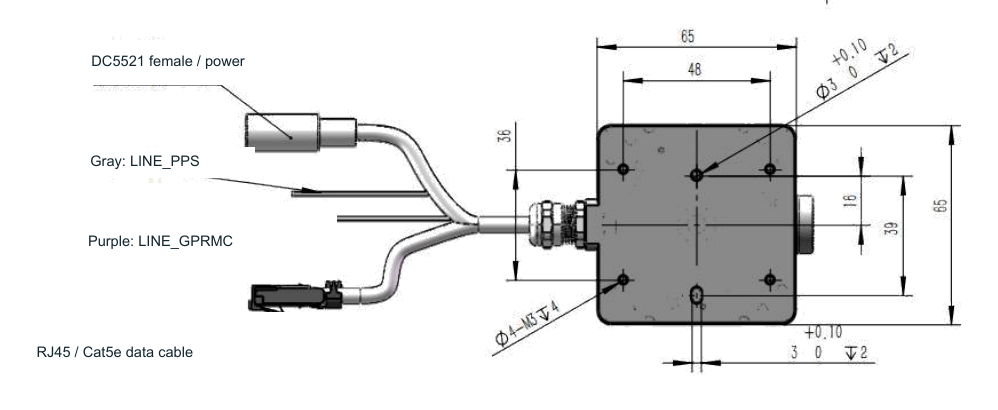
| Item | Published value / condition | Ref. |
|---|---|---|
| Host envelope | 65 x 65 x 61.5 mm; excludes cable | 1.1 |
| Optical / housing callouts | Diameter 65; diameter 61.70; height 61.50; optical-origin callouts 41.78 and 7.46 mm, datums as drawn | 1.1 |
| Mounting reference | 4 x M3 threaded mounting holes, depth 4 mm; pitch 48 x 36 mm as drawn | 1.1 |
| Locating features | Diameter 3 (+0.10 / 0), depth 2; slot width 3 (+0.10 / 0), depth 2; 16 and 39 mm locating callouts as drawn | 1.1 |
| Mass | <260 g, cable excluded | 1.1 |
| Unspecified dimensions | Unspecified tolerance, slot length, complete harness length and final drawing revision: TBD | 1.1 |
| Capability | How it is provided |
|---|---|
| Device interface | Refer to model-specific documentation |
| MQTT | Acquisition and gateway integration available; model-specific scope to agree |
| OTA | Firmware and update lifecycle services available; compatible device scope to agree |
One P60 LiDAR unit; cable / connector accessories are confirmed against the delivered configuration.
Confirm delivery →Specifications, dimensions, interface notes and available SDKs.
View documents →ROGERSENSE P60 is a 360° LiDAR based on a VCSEL transmitter and SPAD receiver using direct time of flight. The V1.1 96-line configuration uses repetitive scanning and provides 960,000 points/s at 10 Hz, a 5 cm minimum range and a 150 m instrument range. A consistent frame-level pattern supports moving platforms; accurate timing and motion compensation remain important.
P60 detection range is 70–80 m, with more than 35 m under 100 klx sunlight. Performance depends on the target and environment. Accuracy is 3 cm (1σ), tested at 30 m using a 50% reflectivity target.
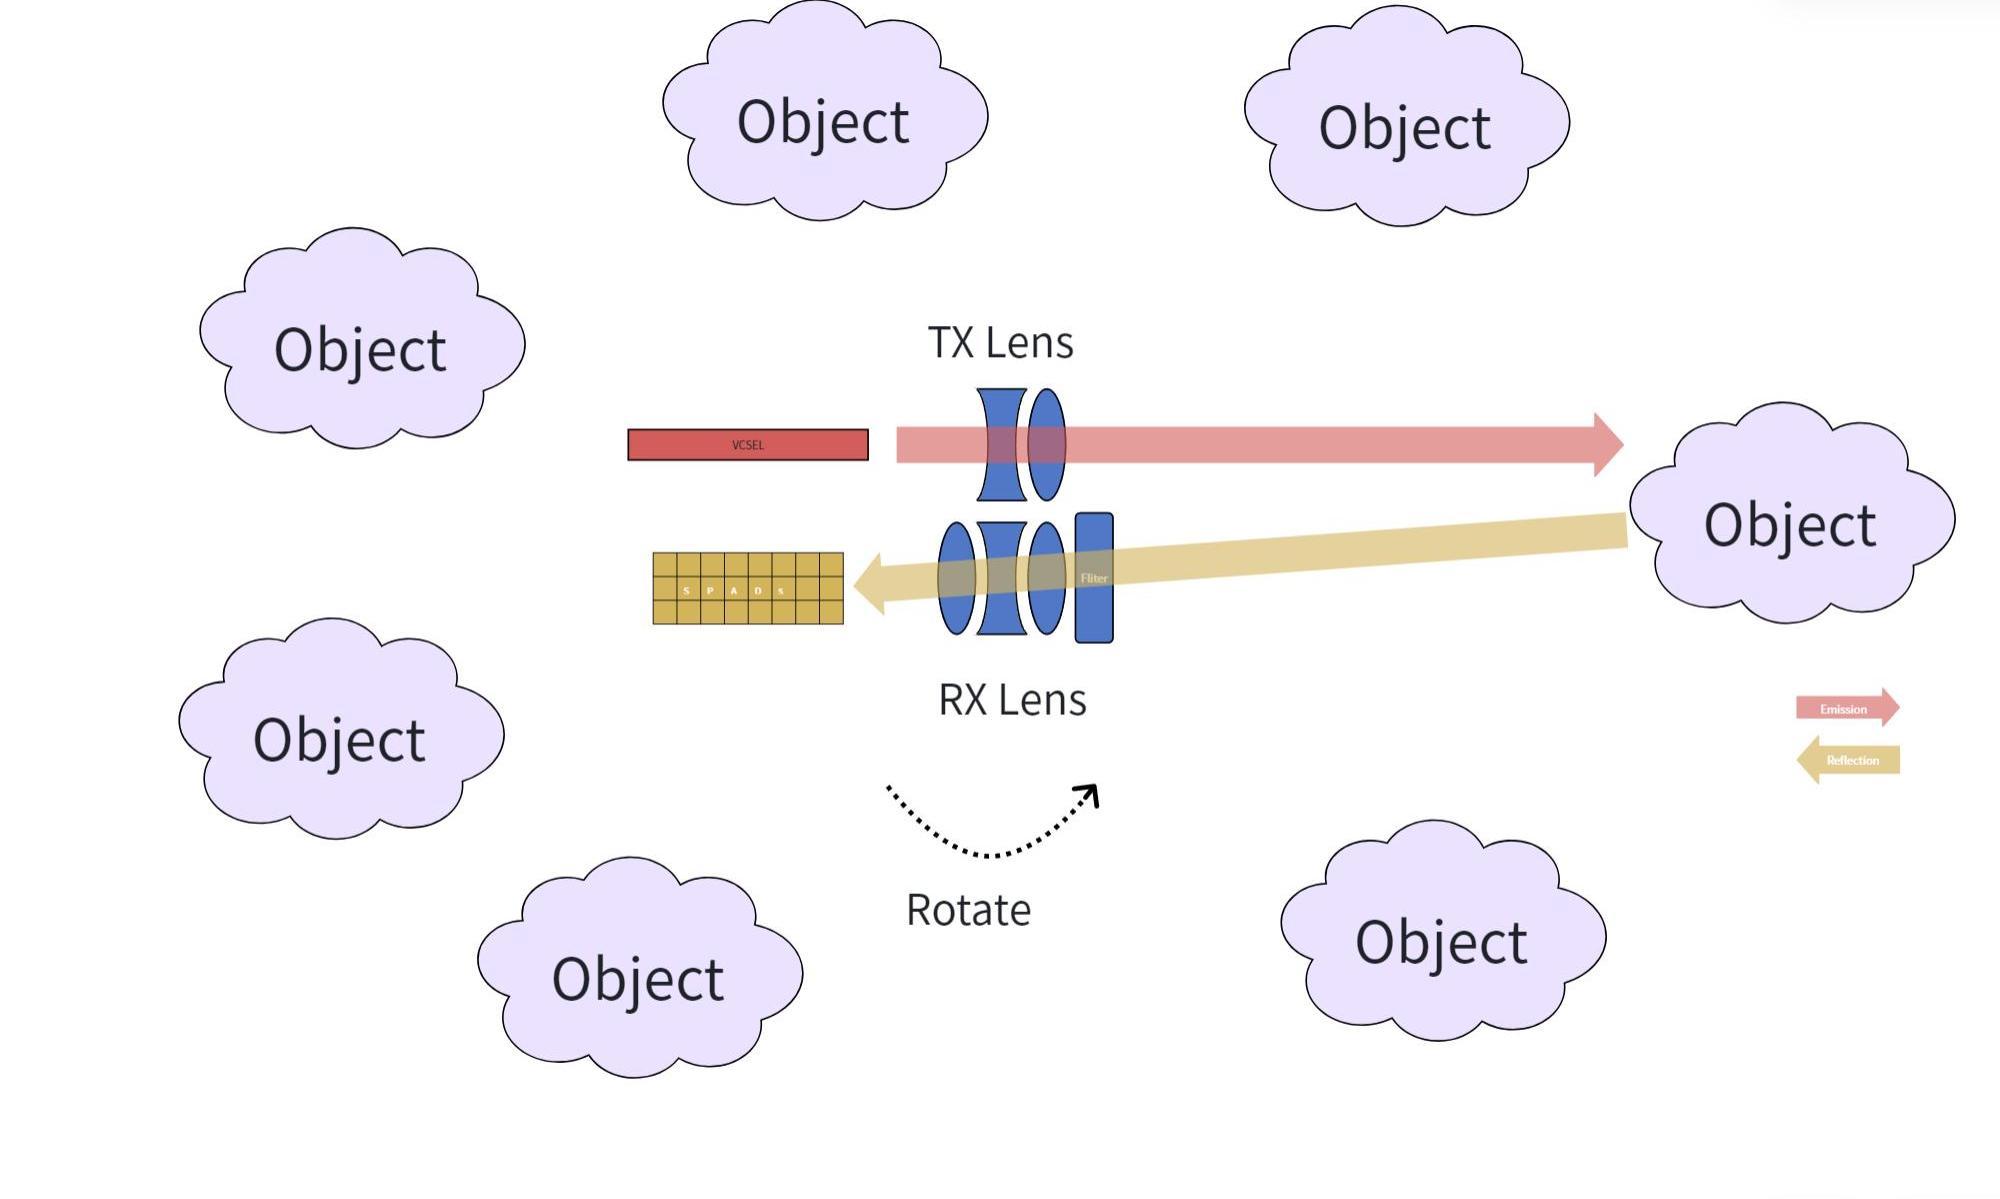
The transmit path runs from the VCSEL through the TX lens to the target. Reflected light passes through the filter and RX lens to the SPAD array. The rotation shown in the original diagram provides surrounding perception: 360° horizontally and -10° to +50° vertically.
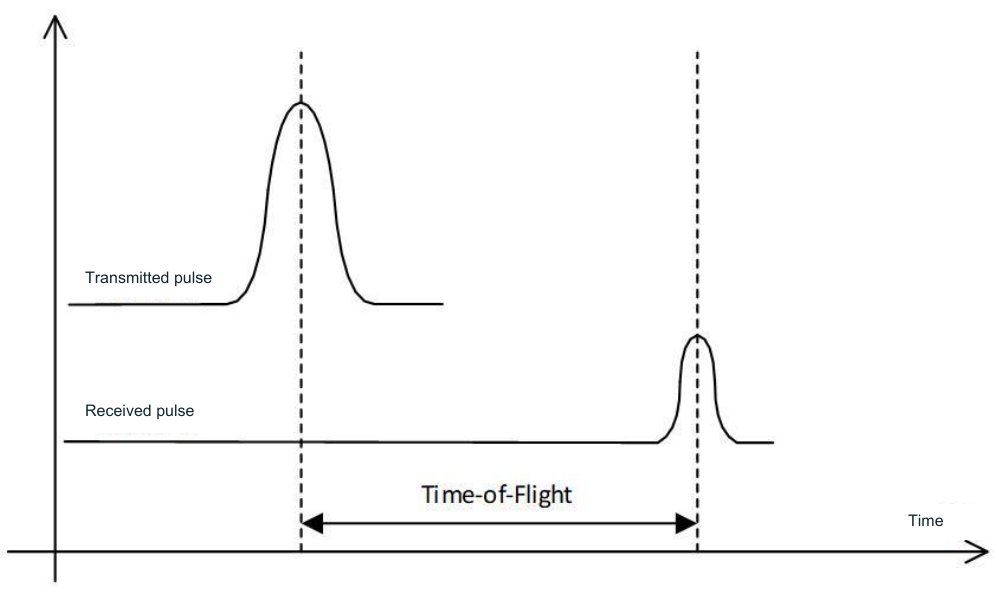
The transmitter emits an ultrashort laser pulse. The target reflects it and the receiver detects the return. Target range is d = c × t / 2, where t is the round-trip flight time and c is the speed of light.
Operating supply is DC 9–32 V with a listed 7 W load. Host data uses 100BASE-T Ethernet at 960,000 points/s, with single-return output selectable as strongest or farthest. Simultaneous dual-return output requires customization. Timing uses PPS and GPRMC. Operating temperature is -40°C to +60°C. The body measures 65 × 65 × 61.5 mm excluding cable, and weighs less than 260 g excluding cable. Mounting and locating dimensions are provided in the V1.1 specification.
Document version 1.1. Unavailable details remain TBD. Certification and test evidence must be confirmed for the delivered configuration. MQTT, OTA, gateway and cloud integration are ROGERSENSE services with model-specific adaptation agreed per project.
No reviews yet.
